Motion and actuation concepts
Eight ways to move, hold and pump things, each designed down to boards, firmware and CAD. Pick a field to see which ones fit and what they could do there.
Design concepts: none of these has been built or tested yet. Every figure is calculated, simulated, taken from a part's datasheet or a design target, and each one says which. Pictures are computer renders from the CAD models. These are our own designs of known ideas; similar products and patents exist.
8 concepts, 82 use cases.
Next: a first prototype
Teaching and research rigs
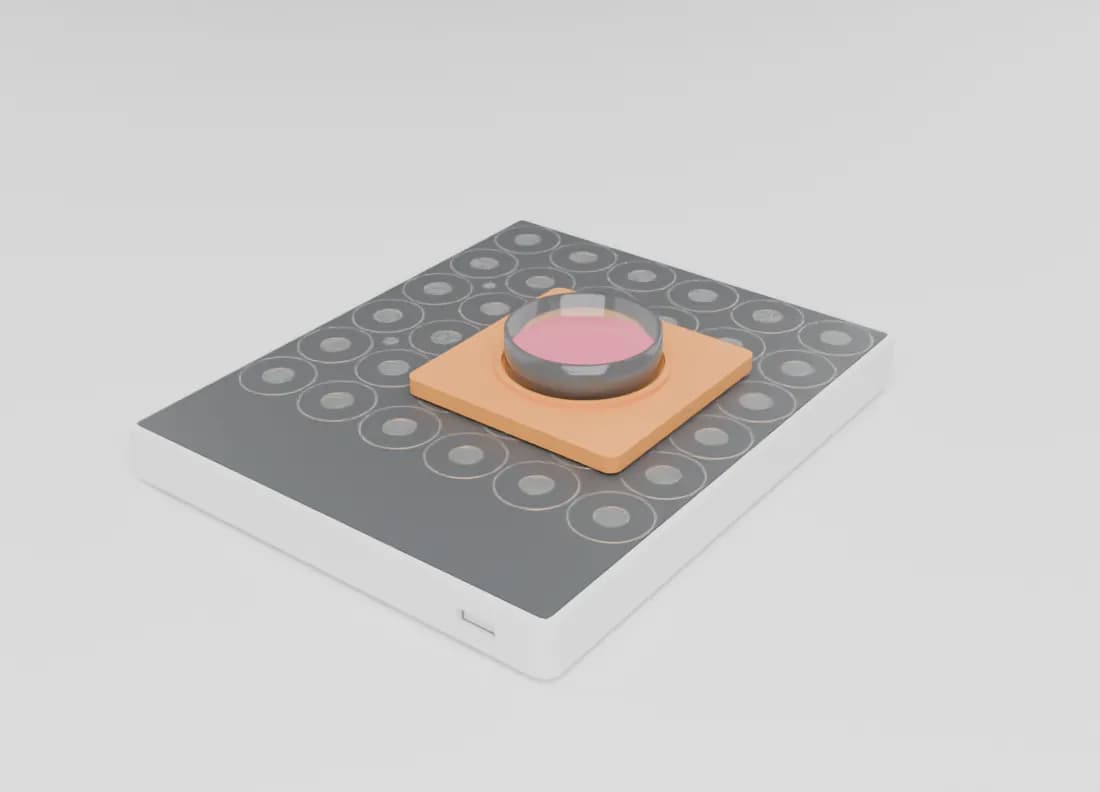
FT-100Levitating planar mover
A desktop tile with 36 coils that floats a 61 mm magnet puck and steers it in two directions, from a USB-C supply. For heavier loads it can slide the puck instead of lifting it.
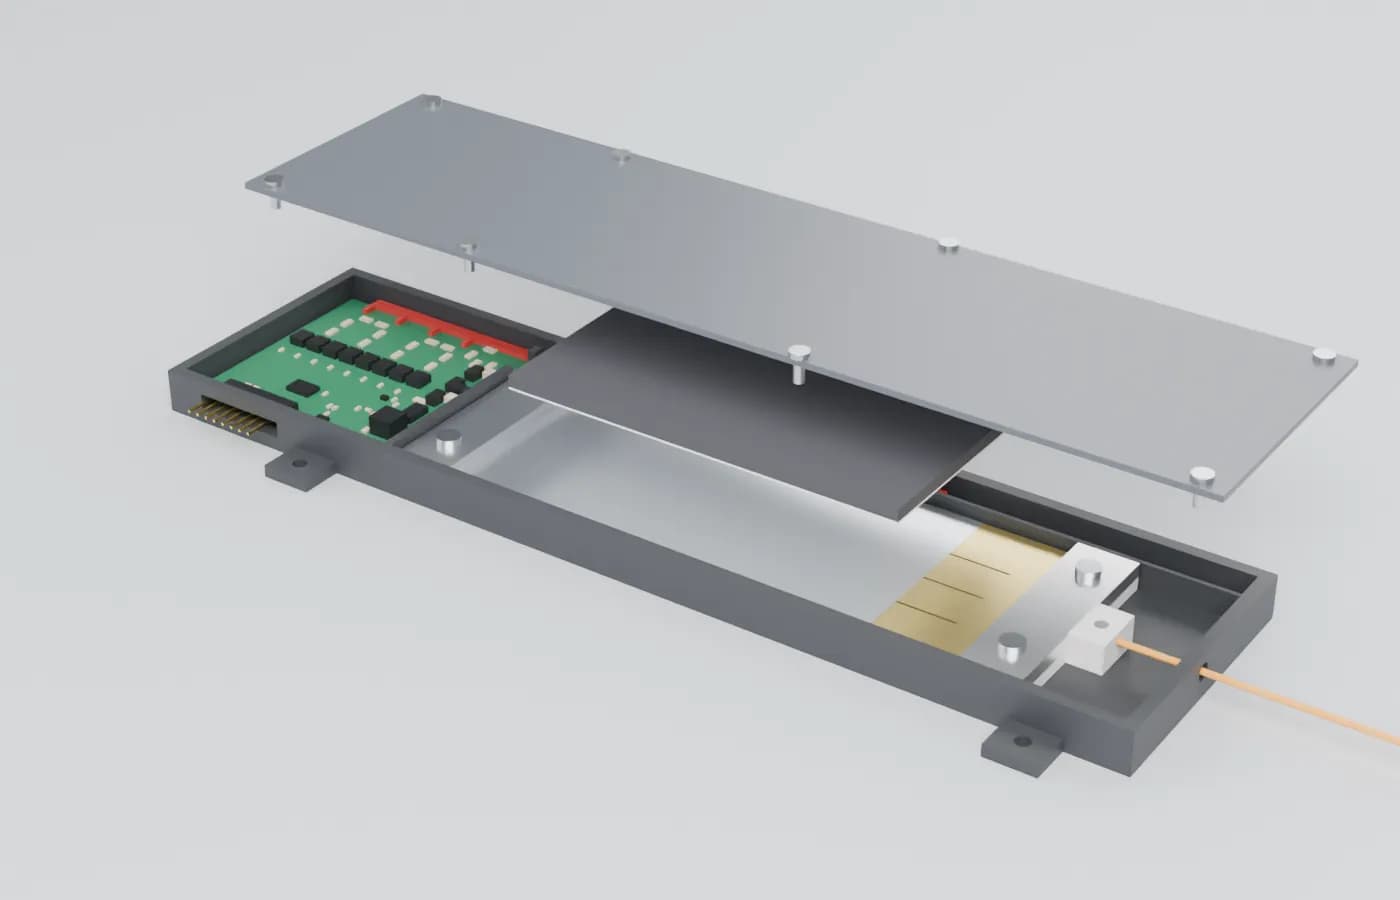
EAC-100Electroadhesive cord clutch
A 12 mm thick clutch for a cord: thin printed films lock together at 300 V and hold about 100 N while using milliwatts, with the safety-limited driver built into the frame.
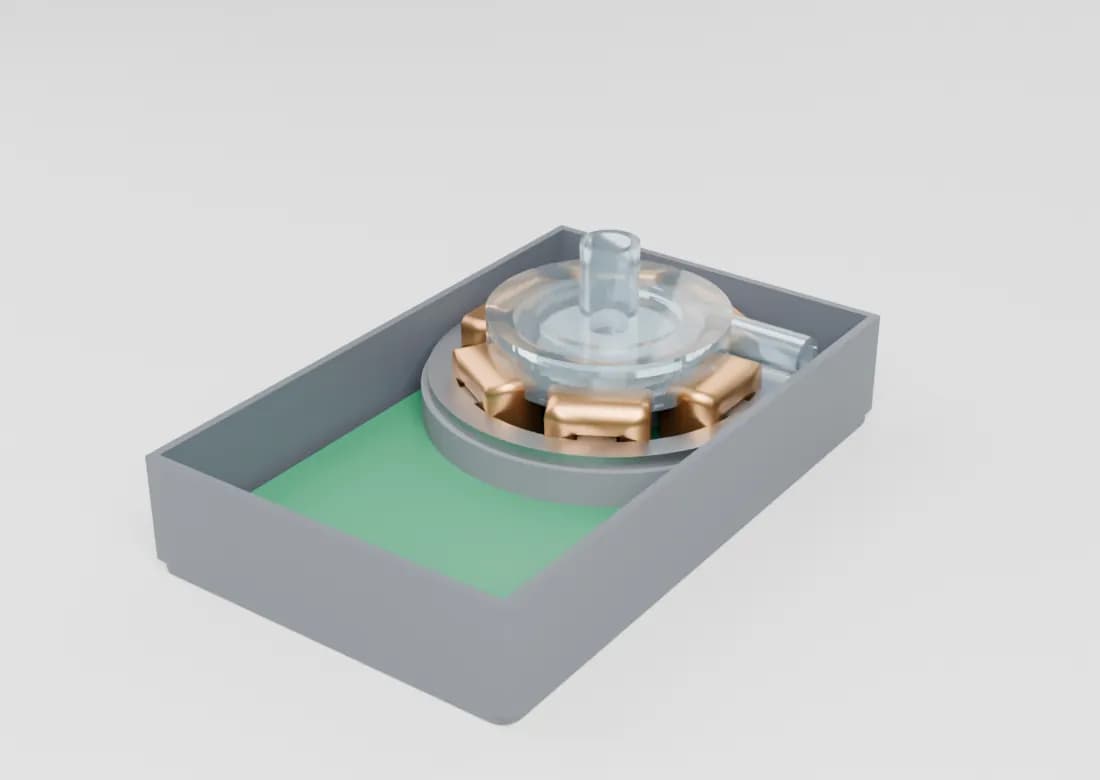
HP-34Levitated lab pump
A small centrifugal pump whose magnet rotor floats inside a sealed chamber: six coils spin and centre it, and sensors on the same board track it through the wall. Nothing touches the liquid but the rotor.
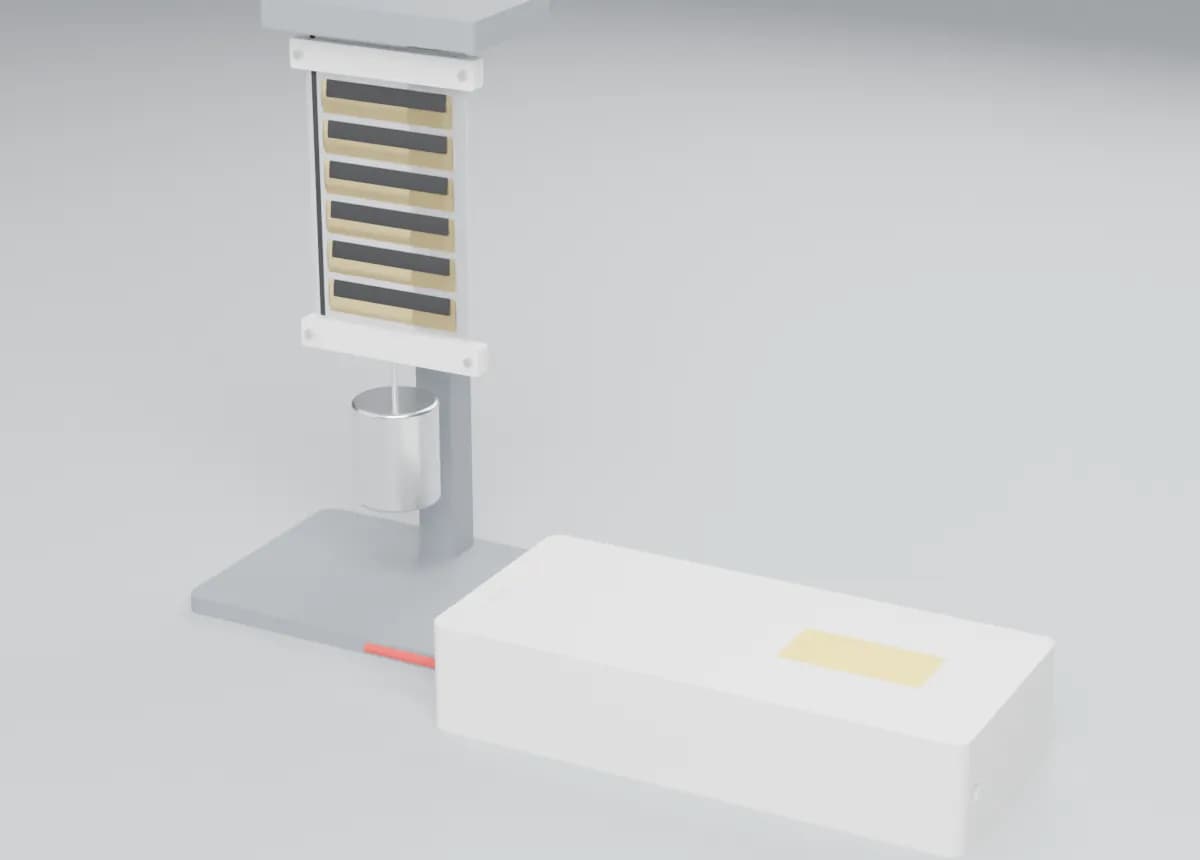
MS-6x50 and HVD-6KSoft electrohydraulic muscle and driver
An oil-filled pouch muscle that contracts when charged, and a 6 kV driver that supplies it at under a milliamp and discharges it quickly.
Design studies
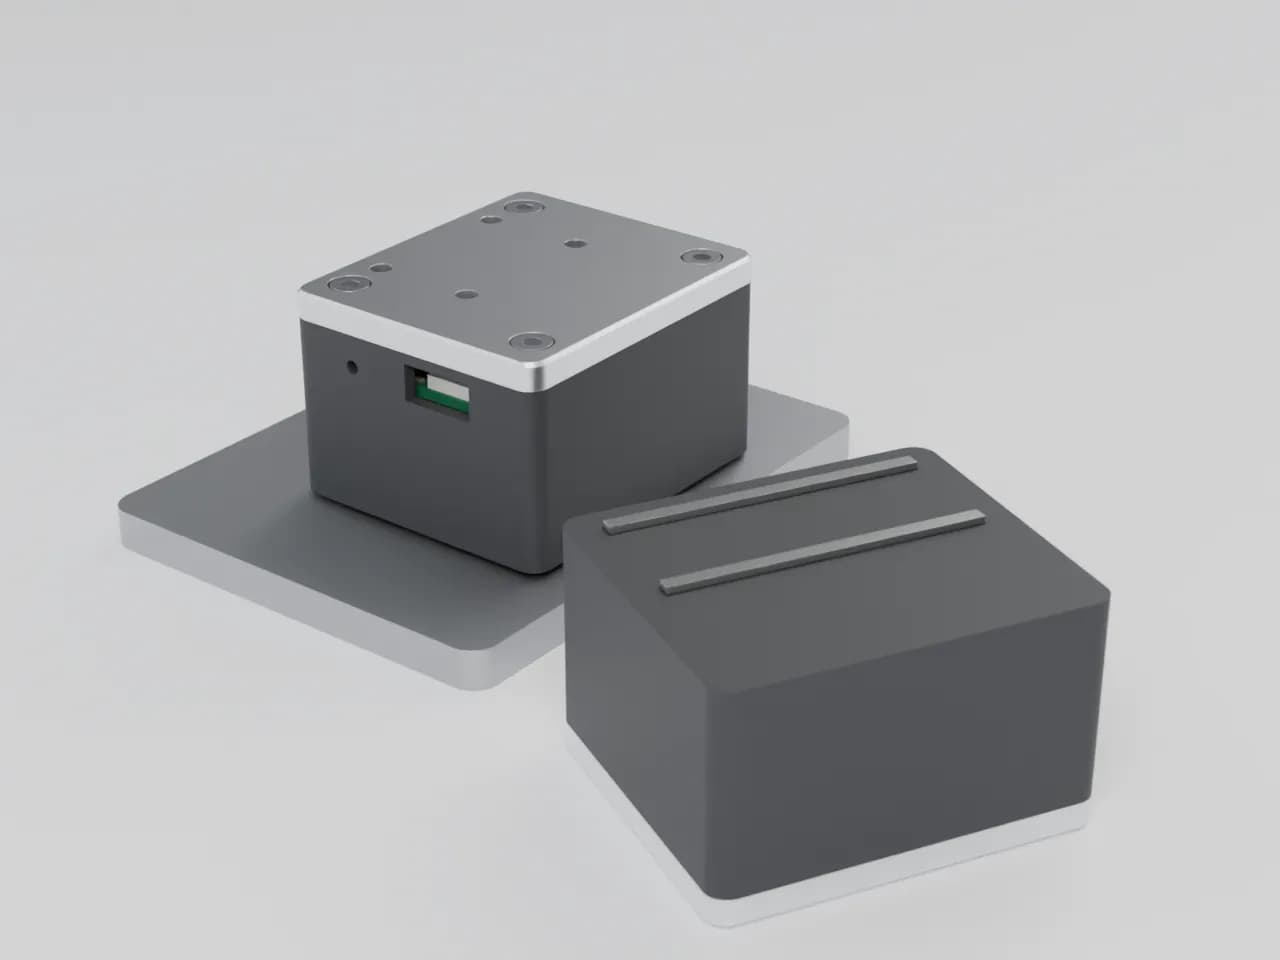
EPG-50Zero-power magnetic gripper
An electropermanent magnet that grips steel parts on one short pulse, releases on another and holds with no power in between, with a sensor that reports whether a part is attached.
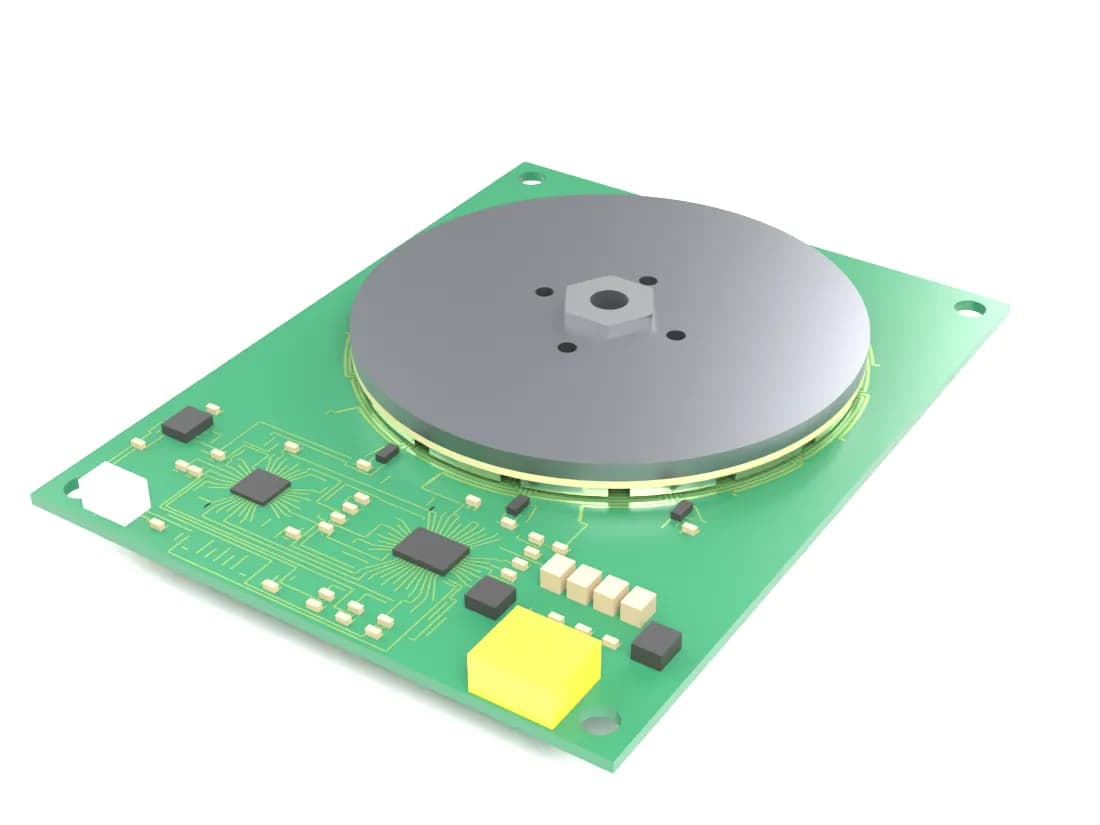
PS80Printed-stator flat motor
A 12.6 mm thick brushless motor whose stator is a six-layer circuit board with twelve etched coils, with its driver and angle sensing on the same board.
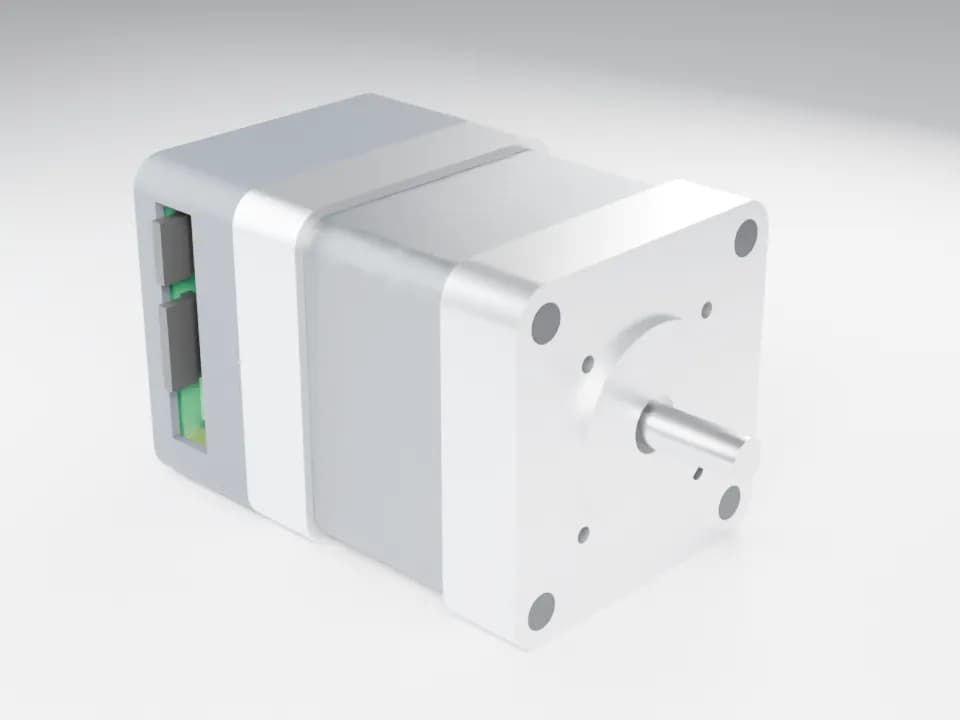
SRM-64Magnet-free motor with driver
A 50 W class, 24 V switched reluctance motor with no magnets and no rare earths, with its three-phase driver board mounted behind it.