MS-6x50 and HVD-6K soft electrohydraulic muscle and driver
An oil-filled pouch muscle that contracts when charged, and a 6 kV driver that supplies it at under a milliamp and discharges it quickly.
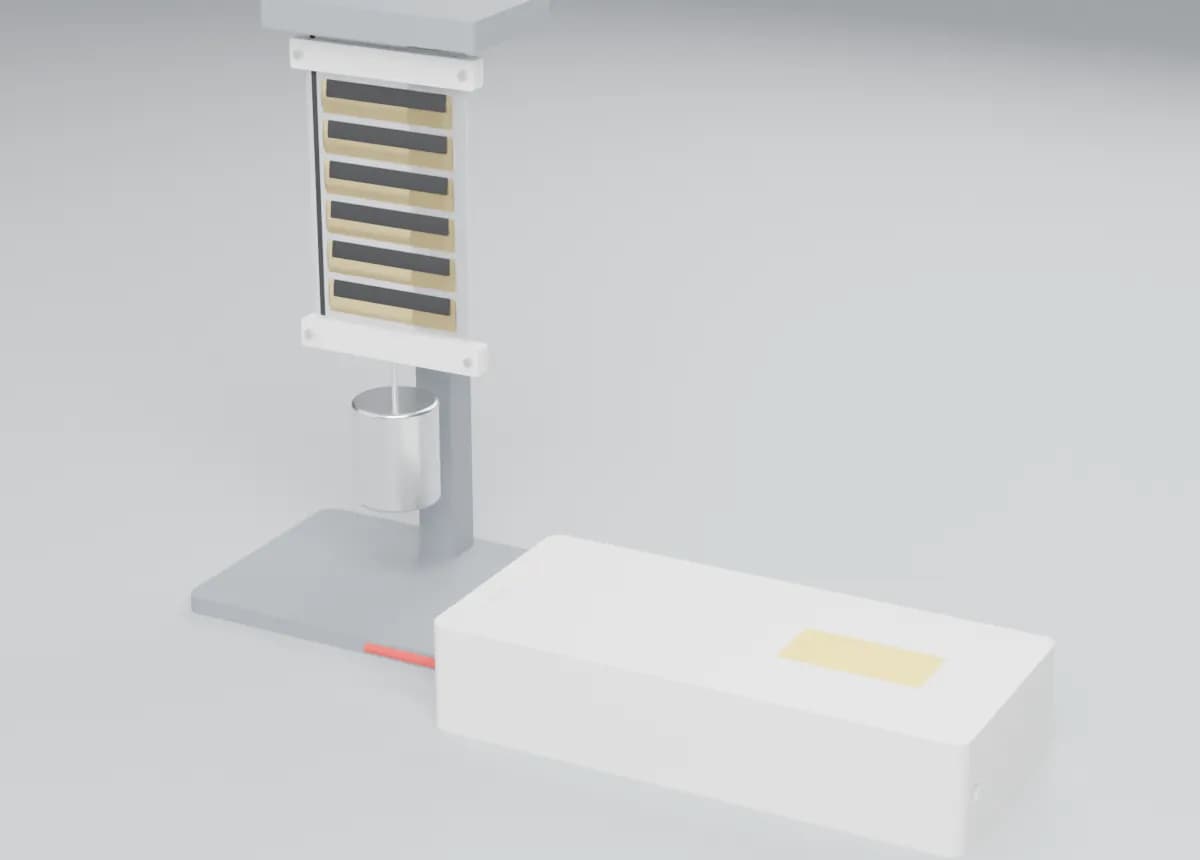
Electrohydraulic muscles are thin plastic pouches filled with oil. Charging electrodes on the pouch squeezes the oil along it, so the pouch shortens and pulls, silently and without a motor. They are an active research area in soft robotics.
The design is a strip of pouches that can be heat-sealed in a lab, and a driver that makes 0 to 6 kV from 5 V, limits its current to well under a milliamp, and pulls the charge back off in milliseconds so the muscle relaxes quickly.
The driver is the part with the widest use: a compact, current-limited high-voltage source for electrostatic actuator experiments.
Design figures
- Driver output
- 0 to 6 kV design target
- Short-circuit current
- about 0.44 mA simulated
- Rise / discharge
- about 21 ms / 7 ms simulated
- Blocking force
- about 14.7 N calculated
- Free stroke
- about 12 mm calculated
- Rated load
- 5 N design target
- Strip
- 109 × 62 mm, 3.4 g design target
Nothing has been built yet, so nothing here is measured.
How it works
Oil in a pouch
A strip of plastic pouches holds a small amount of insulating oil.
Charge squeezes it
High voltage pulls the electrodes together, pushing the oil and shortening the pouch.
Fast discharge
The driver drains the charge in milliseconds and the pouch relaxes.
10 use cases
10 of 10 use cases
- ResearchSoft robotics labsA lab-made muscle and a ready driver for soft-actuator experiments.
- ResearchBio-inspired grippersGentle grippers that close around delicate objects.
- ResearchArtificial muscle testingMeasure force, stroke and life of new pouch designs with one driver.
- ResearchHaptic surfacesRaise and lower small areas of a surface for touch-feedback research.
- ResearchDriver for dielectric elastomersUse the current-limited source for other electrostatic actuators.
- RoboticsSilent actuatorsMotion without motor noise, for robots that work near people in research settings.
- RoboticsLightweight limbsVery light actuators for small research robots.
- Product developmentSoft-actuator feasibilityFind out whether a soft muscle could replace a motor in a product idea.
- ResearchAdaptive optics researchPush gently on a flexible lens or membrane to change its shape.
- ResearchMaterials studiesCompare films and oils for pouch actuators with a repeatable source.
High voltage: this is for supervised research labs only, not for schools, hobby kits or wearables. Pouch muscles of this kind are covered by others' patents.
Where it stands
Design concepts: none of these has been built or tested yet. Every figure is calculated, simulated, taken from a part's datasheet or a design target, and each one says which. Pictures are computer renders from the CAD models. These are our own designs of known ideas; similar products and patents exist.
Designed in-house down to circuit boards, firmware and CAD. The design is proprietary to Senova Systems and is not open source. Interested in this one for your lab or product? Our email is at the foot of every page.