PS80 printed-stator flat motor
A 12.6 mm thick brushless motor whose stator is a six-layer circuit board with twelve etched coils, with its driver and angle sensing on the same board.
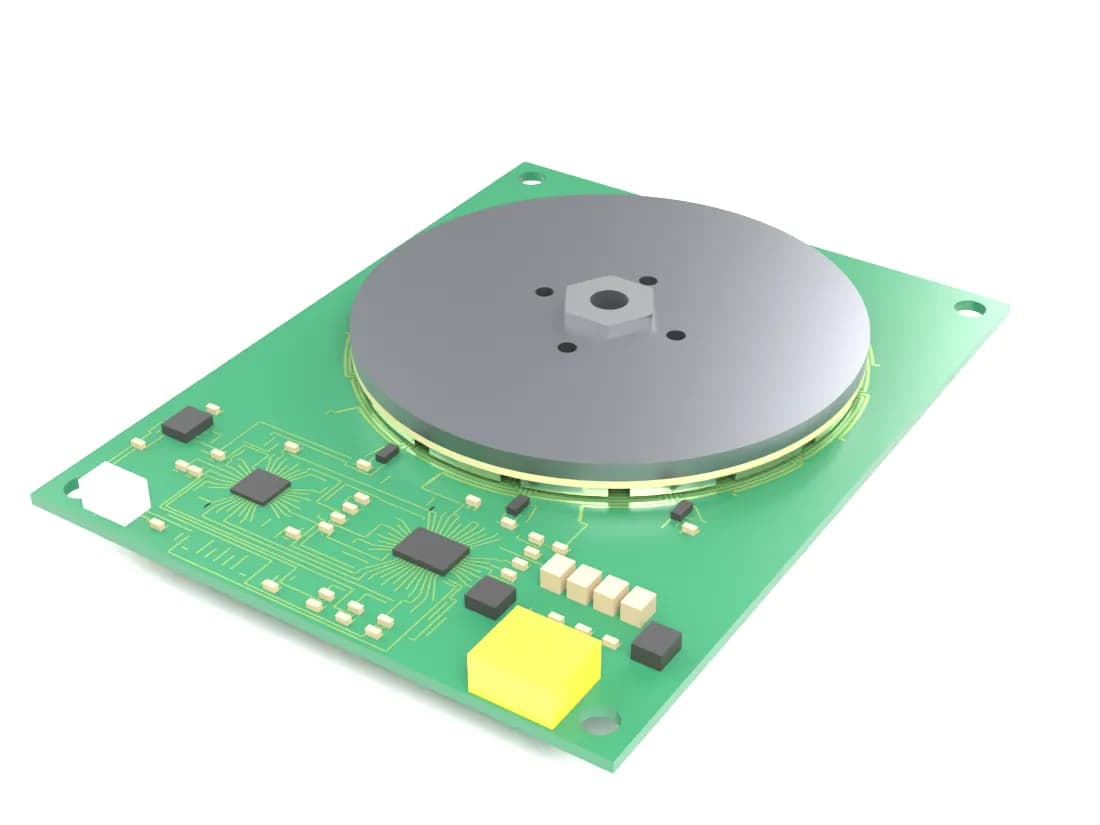
Axial-flux motors with a circuit-board stator have no iron in the stator, so they turn without cogging, and they can be very flat. PS80 puts the drive electronics and the angle sensors on the same board as the coils, so the whole motor with its driver is 12.6 mm thick.
Two magnet rotors sandwich the board; current through the twelve spiral coils turns them. It runs from 12 to 24 V.
Design figures
- Thickness
- 12.6 mm including driver design target
- Continuous torque
- 116 mN·m at stall calculated
- Peak torque
- 348 mN·m for 10 s calculated
- No-load speed
- about 1280 rpm at 24 V calculated
- Cogging
- None (ironless stator) calculated
- Supply
- 12 to 24 V design target
Nothing has been built yet, so nothing here is measured.
How it works
Coils in copper
Twelve spiral coils are etched across six layers of a circuit board.
Magnets either side
Two magnet discs on the shaft sit above and below the board.
Driver on board
The same board carries the motor driver and the sensors that read the rotor angle.
10 use cases
10 of 10 use cases
- Optics and photonicsCamera gimbal axisSmooth, cogging-free rotation for a stabilised camera.
- Optics and photonicsRotating filter wheelTurn a filter or chopper wheel in a slim instrument.
- RoboticsFlat robot jointsA joint motor where thickness matters more than torque.
- Lab automationSample turntableRotate a sample smoothly under a sensor or camera.
- Product developmentThin product drivesFit a motor and its driver into a very slim enclosure.
- Manufacturing and testSmooth-motion test standSpin parts without the ripple of an iron-core motor.
- TeachingMotor design classSee every coil of a motor printed on a board.
- ResearchPCB motor researchA platform for testing coil layouts and drive methods.
- Product developmentHaptic knobsA cogging-free motor that can make a knob feel like anything.
- RoboticsSmall pan-tilt headsPoint a sensor smoothly on a small robot.
Where it stands
Design concepts: none of these has been built or tested yet. Every figure is calculated, simulated, taken from a part's datasheet or a design target, and each one says which. Pictures are computer renders from the CAD models. These are our own designs of known ideas; similar products and patents exist.
Designed in-house down to circuit boards, firmware and CAD. The design is proprietary to Senova Systems and is not open source. Interested in this one for your lab or product? Our email is at the foot of every page.